Robotics Engineer · Manipulation & Control

Shreehan
Santosh Kate

Hey everyone, I'm the reason robots know how to control themselves before they bump into you.

Control Theory / Optimization / Learning

MS Robotics Engineering @ WPI · Directed Research, MER Lab

Move your cursor · live damped least-squares IKTap to steer · live damped least-squares IK

00

// About

The person behind the controller

Shreehan Santosh Kate
SUBJECTShreehan S. KateWorcester, MA

I'm a Robotics MS student at WPI, working at the intersection of kinematics, dynamics, and control for redundant manipulators.

My research spans design optimization of manipulator link geometries for task-specific dexterity, dynamic modeling for control synthesis, and compliant control strategies. I also have an active interest in vision-based control and learning-based approaches to vision problems in robotic manipulation.

Worked & studied with
Worcester Polytechnic Institute National Institute of Technology, Tiruchirappalli xTerra Robotics Mobile Robotics Lab DACAS Lab, IISc Bhatiyani Astute Intelligence
01

// Research & Work

Experience

AUG 2026 — PRESENT
WPI logo

Directed Research Student

Manipulation and Environment Robotics Laboratory · Worcester Polytechnic Institute

  • Ongoing research in force manipulability analysis of three-module, tendon-driven continuum robots
JAN 2026 — MAY 2026
xTerra Robotics logo

Robotics Software Intern

xTerra Robotics · IIT Kanpur

  • Architected a joint and Cartesian impedance control framework in C++ and ROS 2 for stable posture regulation and compliant task space manipulation on a 5-DOF manipulator.
  • Engineered a residual based wrench estimator that maps manipulator induced forces to a floating base whole body controller to keep a quadruped stable during dynamic loco-manipulation.
  • Led the kinematic modeling and link length optimization of a 7-DOF redundant manipulator intended for space applications.
  • Verified forward and inverse kinematic correctness on a physics accurate model in MuJoCo.
View materials ↗
JAN 2026 — MAY 2026
Mobile Robotics Lab logo xTerra Robotics logo

Design and Development of a 7-DOF Redundant Robotic Manipulator

Bachelor's Thesis · NIT Trichy & xTerra Robotics · Guides: Prof. K. Srinivasan, Amritanshu Manu

  • Established the kinematic model of the manipulator using the Craig DH convention.
  • Solved a multi-objective link length optimization problem with NSGA-II, selecting the Pareto knee point design at 2.825 m reach, a 0.147 conditioning number, and a 1.455 manipulability index.
  • Ran singularity analysis via SVD, Cauchy-Binet sub-Jacobians, and a screw dependency framework, benchmarking elbow lock as the dominant singularity and reaching 79.9% well conditioned workspace.
  • Implemented the Recursive Newton-Euler Algorithm at a 5 kg payload for dynamic and static torque calculation and actuator sizing.
  • Built a damped least squares inverse kinematics solver with per mode adaptive Gaussian damping, reaching 100% convergence.
View materials ↗
MAY 2025 — AUG 2025

Research Intern

NIT Tiruchirappalli · Guides: Prof. K. Srinivasan, Prof. T. Shuprajhaa

  • Synthesized a nonlinear control law by deriving the inverse dynamics of a quadrotor UAV to cancel nonlinearities for attitude and altitude control.
  • Proposed a hybrid deep actor-critic reinforcement learning framework supervising an Internal Model Controller for glycemic regulation.
  • Applied transfer learning with a pretrained PPO agent to build an adaptive controller for glycemic levels across diverse Type-1 Diabetes patient models.
View materials ↗
MAR 2025 — JUL 2025

Project Intern

Bhatiyani Astute Intelligence Limited · Bengaluru

  • Prepared image and video datasets in CVAT for computer vision tasks through annotation, preprocessing, and augmentation.
  • Trained and fine-tuned YOLOv5 models for object detection and classification of warehouse inventory items, evaluating performance with mAP and F1-score.
View materials ↗
FEB 2024 — SEP 2025

Research Assistant

NIT Tiruchirappalli · Guides: Prof. Ramakalyan Ayyagari, Prof. Subbareddy Chitta

  • Developed a bio-inspired LQR tuning framework with Genetic Algorithm and Particle Swarm Optimization, reaching 10.4% faster settling time and 20% lower RMSE than analytical tuning.
  • Built an ANN-based autopilot architecture trained on flight data to adapt to nonlinear aircraft dynamics, cutting error by 49.8%.
  • Identified a linear state-space model with the N4SID algorithm and designed a PID controller for a mobile system.
View materials ↗
MAY 2024 — AUG 2024

Drone Research Intern

Indian Institute of Science, Bengaluru · Guide: Prof. Jishnu Keshavan

  • Designed and motion-studied a UAV docking mechanism in Fusion 360 for payload lifting in multi-drone operations.
  • Built an ArUco marker detection pipeline in OpenCV for precision UAV landing on moving UGV platforms.
  • Estimated 6-DoF camera pose with the Perspective-n-Point algorithm from 3D world and 2D image correspondences.
View materials ↗
02

// Selected Work

Projects

Keep scrolling to move along the trackSwipe the track →

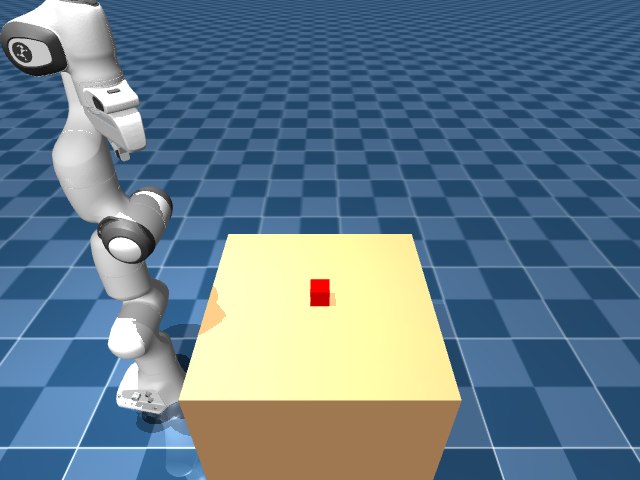
MuJoCo simulation of the Franka Emika Panda arm performing perception-guided pick and place
P/01Active · Manipulation

Perception & Control Pipeline for Redundant Manipulators

Implemented a 6-DOF Cartesian impedance controller for compliant manipulation, reaching 3.8 mm peak and 0.14 mm steady state tracking error. Built a two-camera 3D localization pipeline for the Franka Emika Panda in MuJoCo, achieving 1.4 mm position and 0.1 degree yaw accuracy without learned models. Closed the loop with a pick and place system combining wrist camera pose refinement, damped least squares IK, and contact triggered grasping, validated across 50 randomized trials with a 100% success rate.

Jan 2026 — PresentGitHub ↗
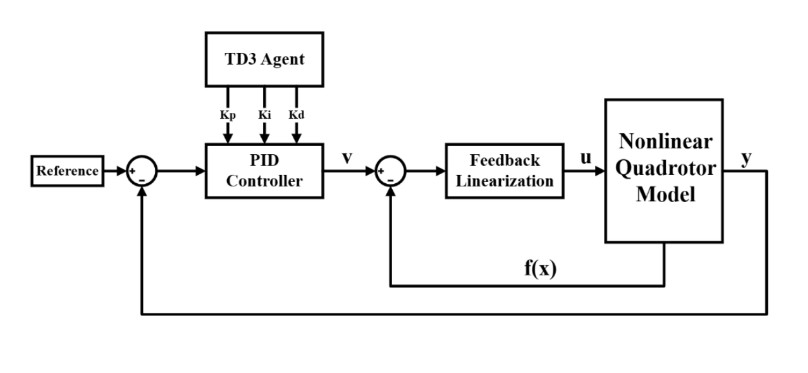
Block diagram of the TD3 agent tuning a PID controller with feedback linearization for the nonlinear quadrotor model
P/02Reinforcement Learning

Adaptive Control of Quadrotor UAVs

Trained TD3 and DDPG actor critic agents to dynamically tune controller gains, with a reward function shaped on LQG cost. Demonstrated disturbance rejection under external perturbations and reached 60% lower cumulative tracking error than fixed gain PID, LQR, and LMPC baselines.

May 2025 — Aug 2025GitHub ↗
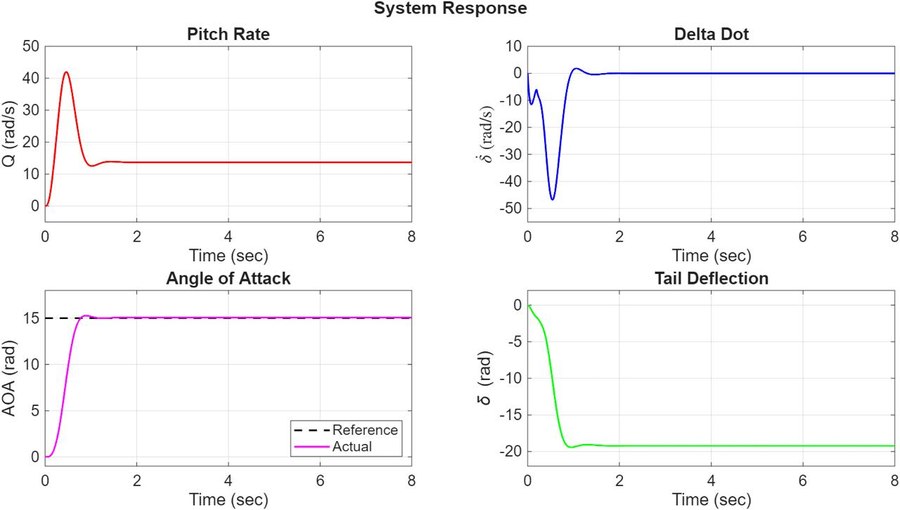
System response plots for pitch rate, angle of attack, and tail deflection of the missile autopilot
P/03Nonlinear Control

Fuzzy-Tuned LQR for Cruise Missile Autopilot

Derived a quasi linearized fourth order inner loop model from a nonlinear longitudinal missile autopilot using feedback linearization. Designed a Mamdani Type 1 fuzzy inference system in MATLAB for online adaptation of LQR weights, improving autopilot robustness by 28.92% over offline tuning.

Mar 2024 — Jun 2024GitHub ↗
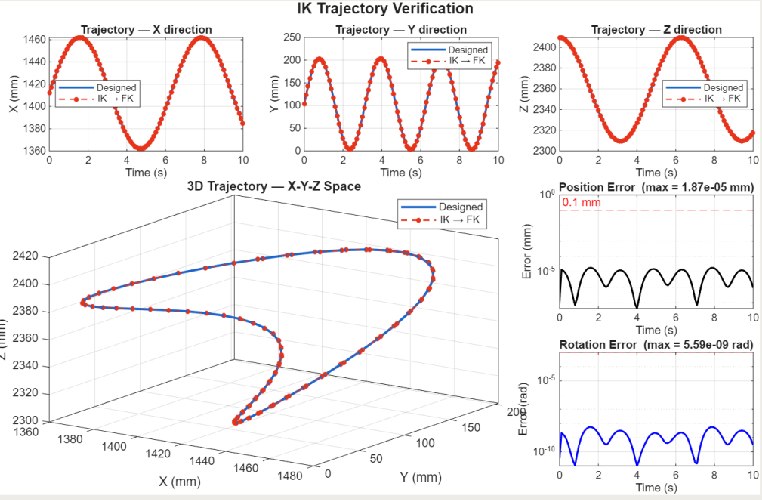
IK trajectory verification plots showing designed versus IK to FK tracking in X, Y, Z and position and rotation error
P/04Dynamics

7-DOF Redundant Manipulator for Space Applications

Built the kinematic model with the Craig DH convention and optimized link lengths with NSGA-II. Computed actuator torques with the Recursive Newton-Euler Algorithm at a 5 kg payload. Solved inverse kinematics with a damped least squares solver using adaptive Gaussian damping, reaching 100% convergence.

Jan 2026 — May 2026Materials ↗
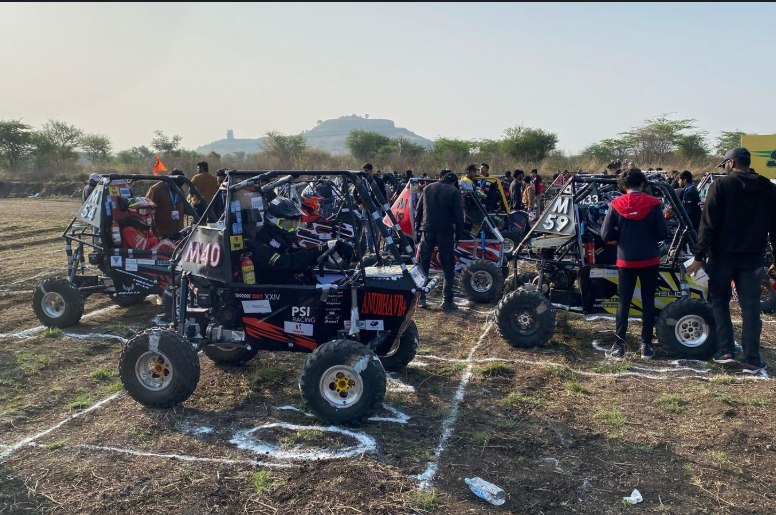
All-terrain vehicle at mBAJA 2024 with the team's car in the foreground
P/05Vehicle Dynamics

Suspension and Steering Design for an All-Terrain Vehicle

Worked within a 15-member team on the conceptualization, analysis, and validation of the suspension and steering system for a 4WD all-terrain vehicle, from design through fabrication. Reduced front and rear track widths by 3.77% and 2.13% to improve off-road handling, contributing to a 19th place finish at mBAJA 2024, organized by SAE India.

Aug 2023 — Aug 2024Materials ↗
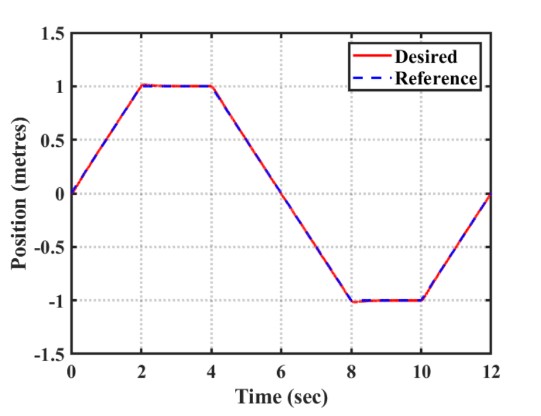
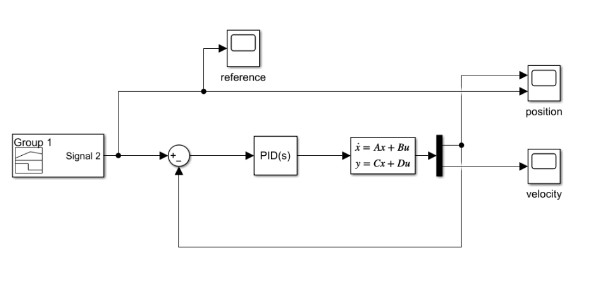
Closed-loop position tracking plot showing the desired and reference trajectories overlapping Simulink block diagram of the PID controller closing the loop around the identified state-space model
P/06System Identification

System Identification and Control of a Mobile Robot

Identified a discrete-time linear state-space model of a mobile robot's nonlinear dynamics with the N4SID algorithm, using recorded acceleration and control input data. Tuned a PID controller on the identified model with the Ziegler-Nichols method and validated closed-loop tracking and stability in Simulink.

MATLAB & SimulinkGitHub ↗
EOF More on GitHub ↗
03

// Research Output

Publications & Conferences

[1]
Accepted

Adaptive PID Control for Quadrotor UAVs Using Feedback Linearization and Deep Reinforcement Learning

International Conference on Smart Computing, Communication & Secure Technologies (ICSCCST)

Read paper ↗
[2]
Presentation Done

Deep Reinforcement Learning Framework for Adaptive Control of Swing-up Inverted Pendulum

5th International Conference on Emerging Electronics and Automation (ICEEA)

Read paper ↗
[3]
Published

Bio-Inspired Optimization of LQR Controllers for Feedback-Linearized Cruise Missiles

9th International Conference on Inventive Systems and Control (ICISC)

View on IEEE Xplore ↗
04

// Academic Background

Education

FALL 2026 — PRESENT

Master's in Robotics Engineering

Worcester Polytechnic Institute · Worcester, MA

Fall 2026 coursework: Vision-based Robotic Manipulation, Robot Control
Directed Research at the Manipulation and Environmental Robotics Lab

NOV 2022 — MAY 2026

B.Tech, Instrumentation & Control Engineering

National Institute of Technology, Tiruchirappalli · CGPA 8/10

NITT Undergraduate STEM Research Fellowship Awardee.

05

// Recognition

Awards & Certifications

Award

NITT Undergraduate STEM Research Fellowship

Top Merit Award · RECAL, The Alumni Association of NIT Trichy

Awarded a research grant of ₹70,000 for a proposal on adaptive reinforcement learning for predictive control of autonomous quadrotor systems.

View certificate ↗
Certification

Reinforcement Learning

NPTEL · IIT Madras, Instructor: Dr. B. Ravindran

View certificate ↗
Certification

Drone Systems and Control

NPTEL · IISc Bangalore, Instructor: Dr. Suresh Sundaram

View certificate ↗
06

// Toolset

Skills

S/01

Robotics

Manipulator KinematicsDynamicsImpedance Control Trajectory PlanningSingularity AnalysisWhole-Body Control
S/02

Coding

MATLABPythonC++ROS 2
S/03

Frameworks

PyTorchOpenCVNumPyMuJoCo
S/04

Engineering Software

SimulinkFusion 360AutoCADGazebo

// 07 · Get in Touch

Let's connect.

Reaching out about manipulation research, control systems, or WPI? Happy to talk. Best by email or LinkedIn.